> For the complete documentation index, see [llms.txt](https://docs.deltaquad.com/tac/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.deltaquad.com/tac/flight/planning-a-mission/set-intermediate-waypoints/stealth-switch.md).
# Stealth Switch
This section explains how to plan a mission that facilitates the stealth switch.
{% hint style="info" %}
The **Stealth Switch** is a feature that allows the DeltaQuad Evo to turn off all radio emissions, making it undetectable to interception systems. When activated, the vehicle disables all radio transmissions, ensuring it operates in complete stealth mode.
The operator can plan missions with predefined stealth operation phases using **Auterion Tactical Stack Avionics**. The drone autonomously executes these stealth phases and then reconnects with the operator at a designated point in the mission.
{% endhint %}
{% hint style="warning" %}
To ensure a successful stealth operation, the settings for the **Data Link Loss Failsafe Trigger** are always ignored and set to disabled by default during mission plan execution. This prevents the stealth mission from being aborted (e.g., by initiating Return-to-Launch) if radio transmission is cut.
{% endhint %}
* To use the **Stealth** **Switch**, a **mission** **plan** must be created. Plan a **VTOL Takeoff** and **Transition**, along with **Intermediate** **Waypoints**, up to the location where you wish to engage the **Stealth** **Switch**. Please review the instructions for planning a [**VTOL Takeoff, Transition**](/tac/flight/planning-a-mission/mission-start-action.md), and [**Intermediate Waypoints**.](/tac/flight/planning-a-mission/set-intermediate-waypoints.md)
* To engage the **Stealth Switch**, an additional waypoint must be planned, which will be set as a **Custom** **Action Command**.
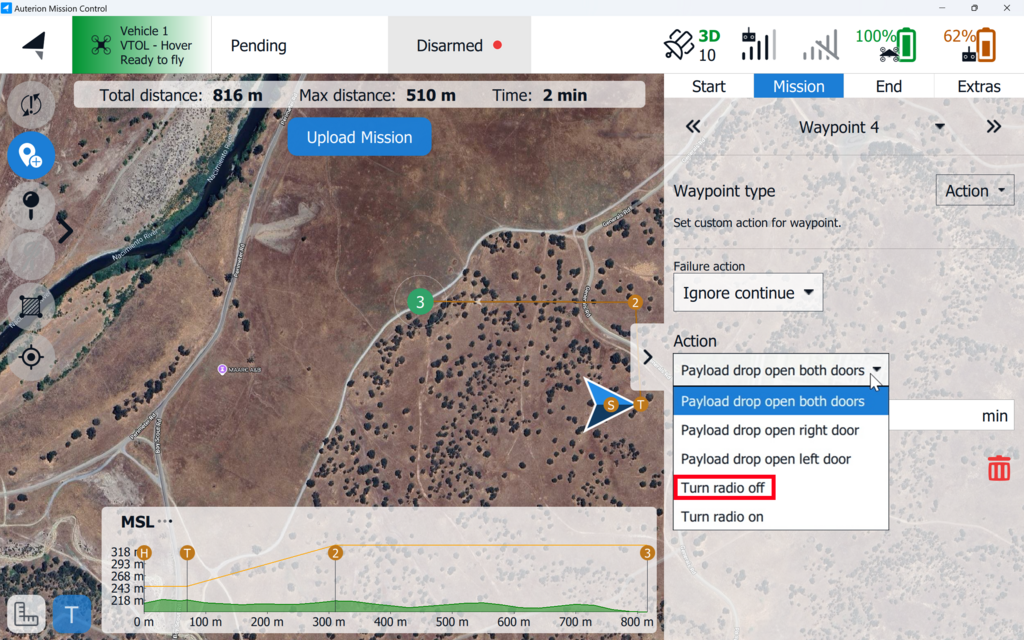
1. Create a **waypoint** at the location and altitude where the **Stealth Switch** should be engaged. In the example below, the **Stealth Switch** should be engaged at **waypoint 3**.
2. Create a **waypoint** anywhere on the **map**.
3. In the **Mission Editor**, on the right side of the screen, click on the **Waypoint type (Waypoint)**.
4. A menu will open, allowing you to **Select** a **Waypoint Type,** choose **Action.**
5. As soon as the **Waypoint Type** is set to **Action**, **Waypoint 4** will be attached to **Waypoint 3** as a **Custom Action.**
6. In the **Mission Editor**, the **Action tab** is available on the right side of the screen. When you click on it, a drop-down menu will appear. Select **Turn radio off**.
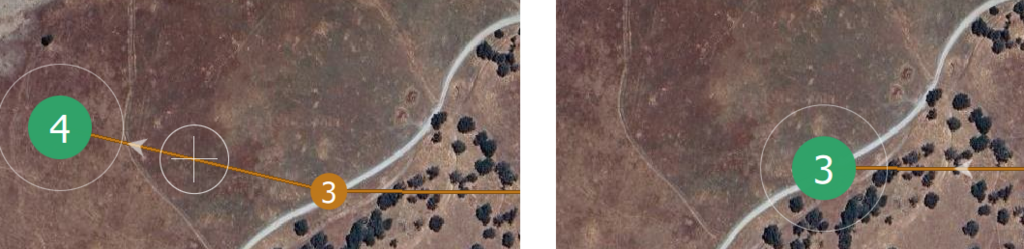
7. We have now planned for the **Stealth Switch** to engage at **Waypoint 3**. From that point onward, all subsequent waypoints will be flown **without** any **radio emissions**, meaning no radio connection to the GCS. Now, let’s plan the next **waypoint** where the **Stealth Switch** will disengage. We will place this at **Waypoint 4**, just beyond the riverbed.
8. If we now click on the **Waypoint Summary** at the top of the **Mission Editor**, the **Custom Action** attached to **Waypoint 3** is listed as **Action**.
{% hint style="info" %}
Since **Custom Actions** are not displayed on the map, the only way to access and change their settings is through the **Waypoint Summary**.
{% endhint %}
9. We create another **Waypoint** anywhere on the map, which will be set as the **Custom Action** to disengage the **Stealth** **Switch**. In the **Mission Editor**, on the right side of the screen, click on the **Waypoint type (Waypoint)**.
10. A menu will open, allowing you to **Select** a **Waypoint Type,** choose **Action.**
11. As soon as the **Waypoint Type** is set to **Action**, **Waypoint 5** will be attached to **Waypoint 4** as a **Custom Action** to disengage the **Stealth Switch.**
12. In the **Mission Editor**, select **Turn radio on** from the **drop-down menu** in the **Action tab**.
13. After a few seconds, the **Radio Connection** with the **GCS** should be re-established. From this point, the mission can continue with another **Stealth Switch** activation or a **landing** at the **home position**.
{% hint style="info" %}
In **fixed-wing UAVs (Unmanned Aerial Vehicles)**, the **acceptance radius** refers to the radius around a waypoint within which the UAV considers itself to have **reached** that waypoint and can proceed to the next. It’s a tolerance value, typically measured in meters, that allows for slight deviations due to wind or other factors affecting flight path accuracy.
For **fixed-wing UAVs**, the **acceptance** **radius** is usually larger compared to **rotary-wing UAVs** because fixed-wing aircraft can’t make sharp turns and require a smoother, more gradual transition between waypoints.
Typical acceptance radius values for **fixed-wing UAVs** range from **5 to 50 meters**, depending on factors like mission type, aircraft speed, and waypoint precision required. If the UAV enters this radius, it will consider the waypoint achieved and adjust its heading toward the next one.
{% endhint %}
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.deltaquad.com/tac/flight/planning-a-mission/set-intermediate-waypoints/stealth-switch.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.