> For the complete documentation index, see [llms.txt](https://docs.deltaquad.com/gov/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.deltaquad.com/gov/flight/quick-takeoff/land-approach.md).
# Land Approach
This section outlines the steps involved in planning the Land Approach.
1. To plan a **Quick Takeoff**, the **DeltaQuad Evo** must be connected to the **GCS**.
2. Position the vehicle at the desired takeoff location.
3. Ensure the **nose** of the vehicle is **pointed into** the **wind**.
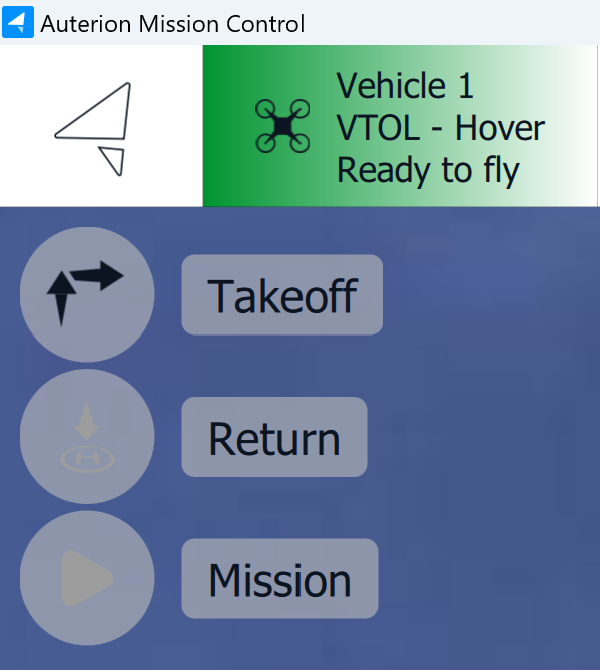
4. In the **Fly View**, click on the **Takeoff** command.
## Land Approach Settings
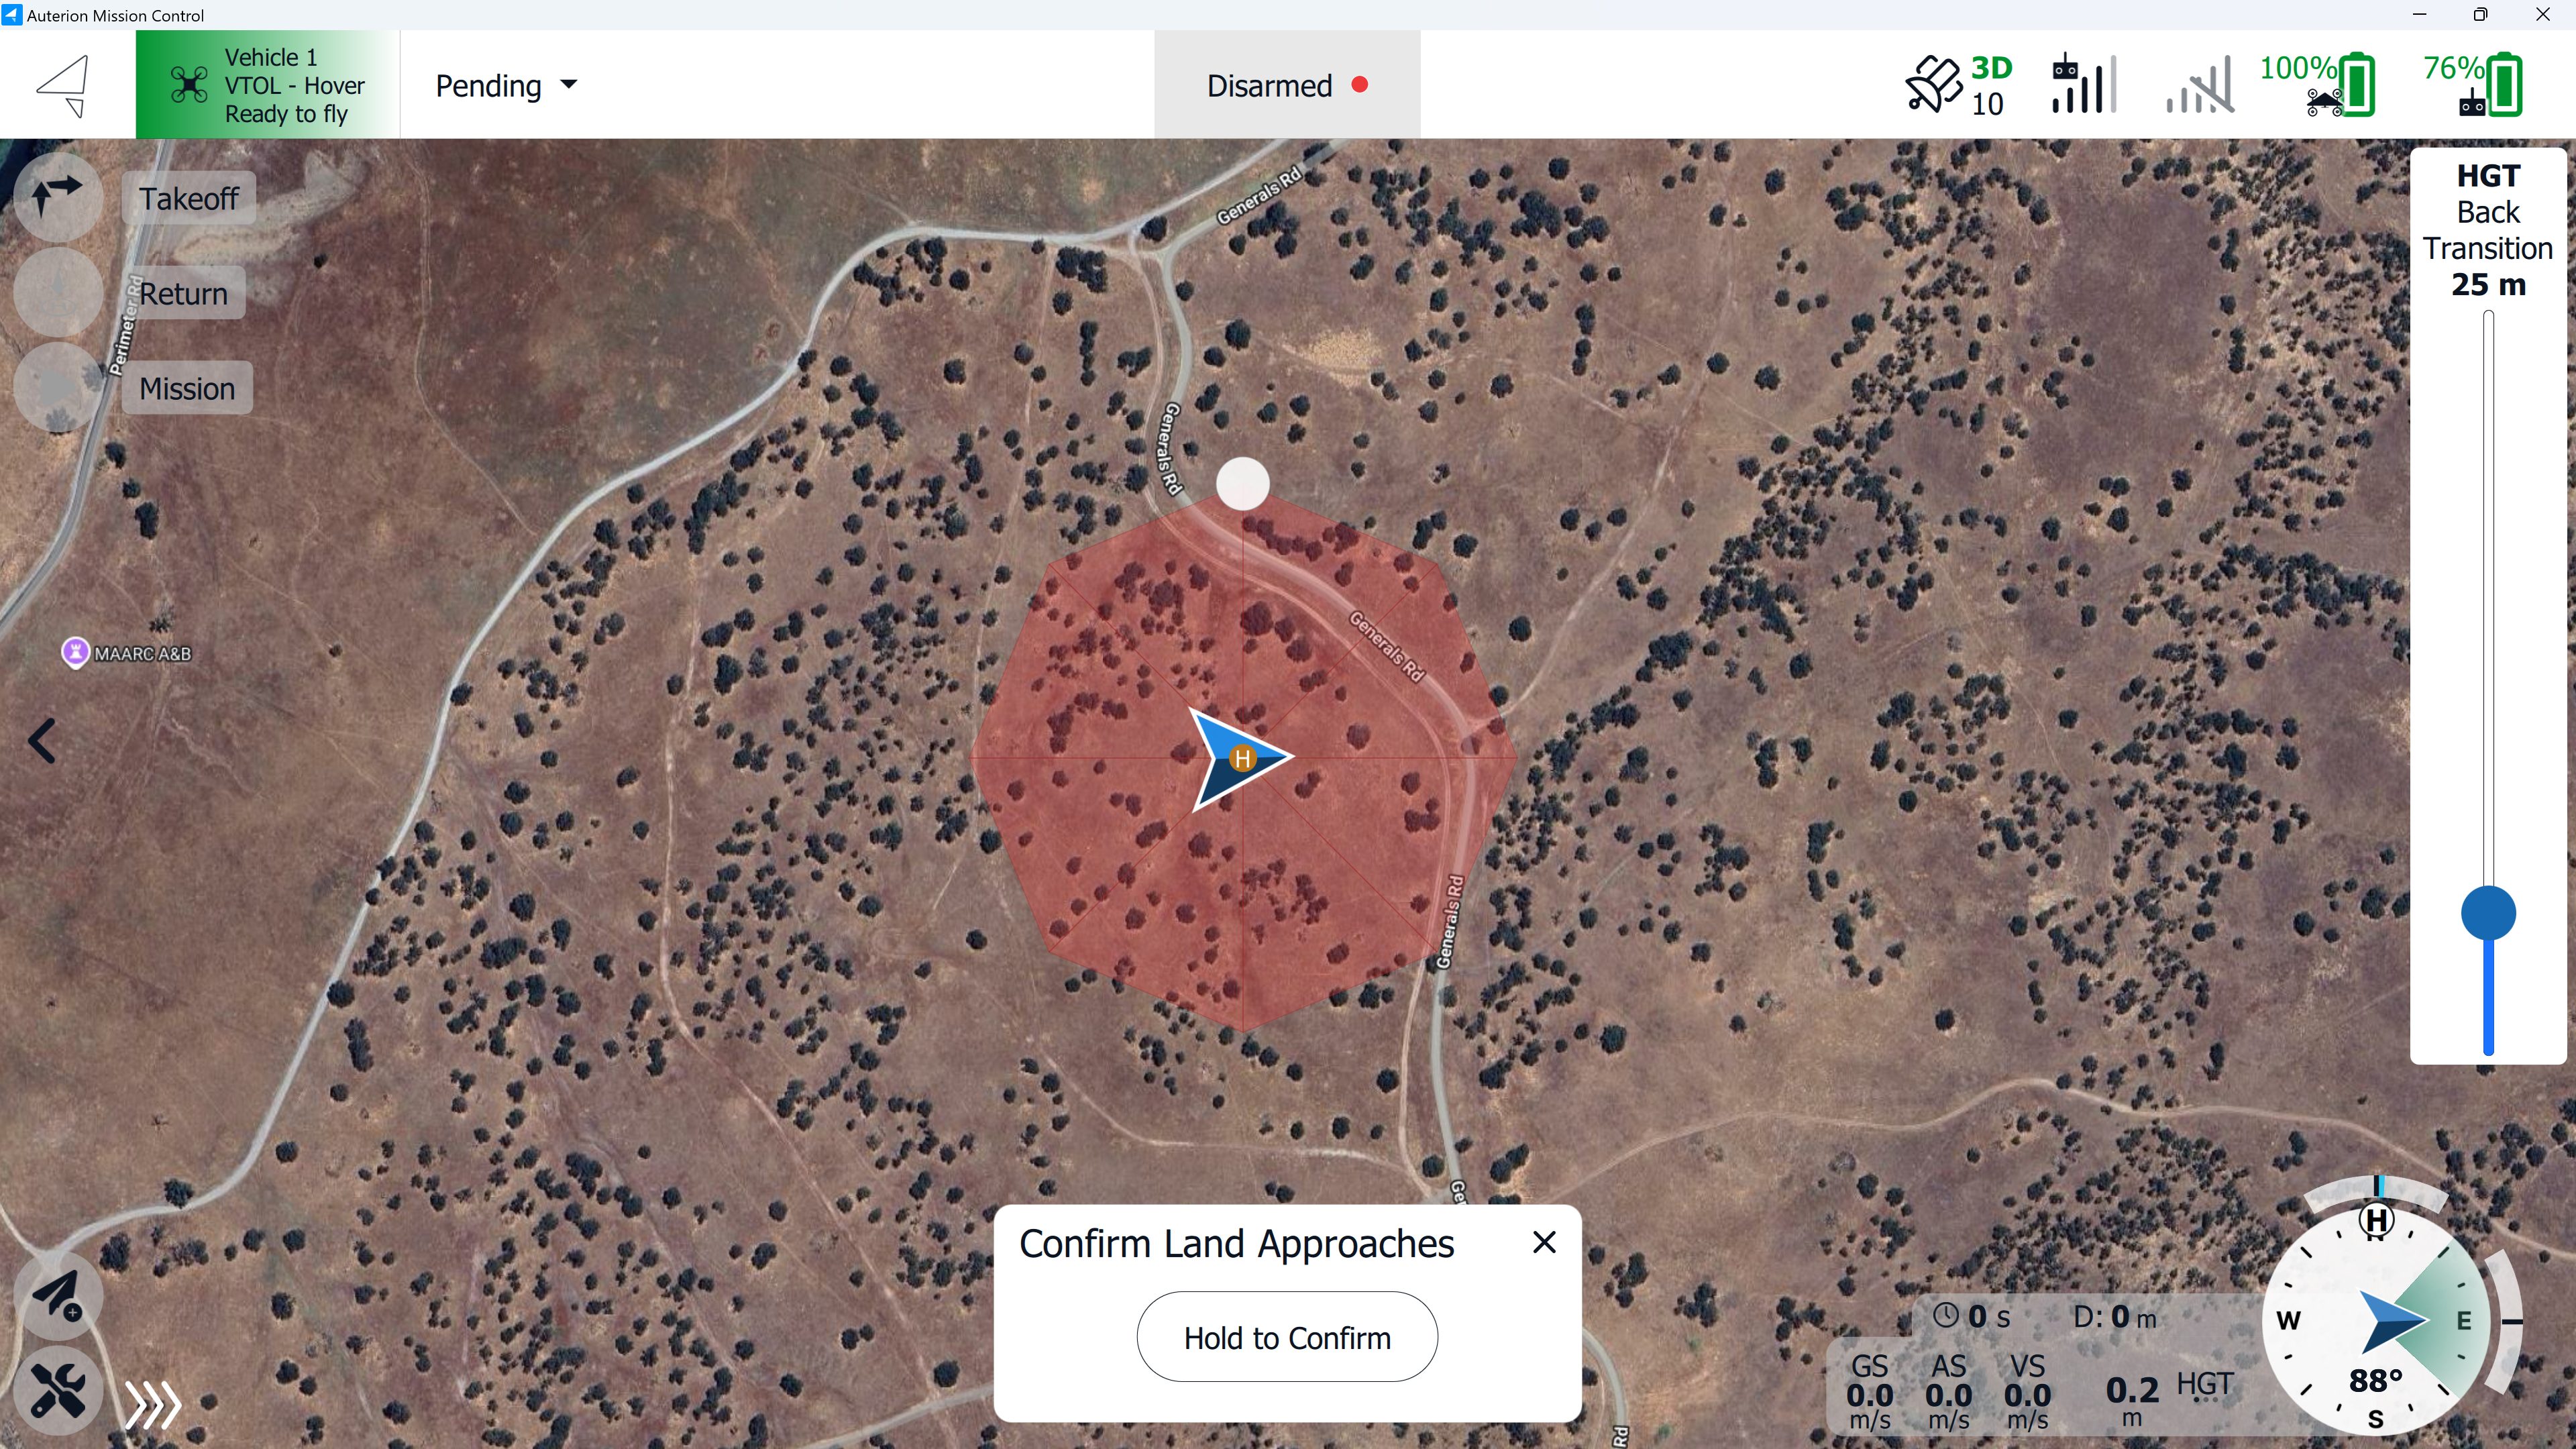
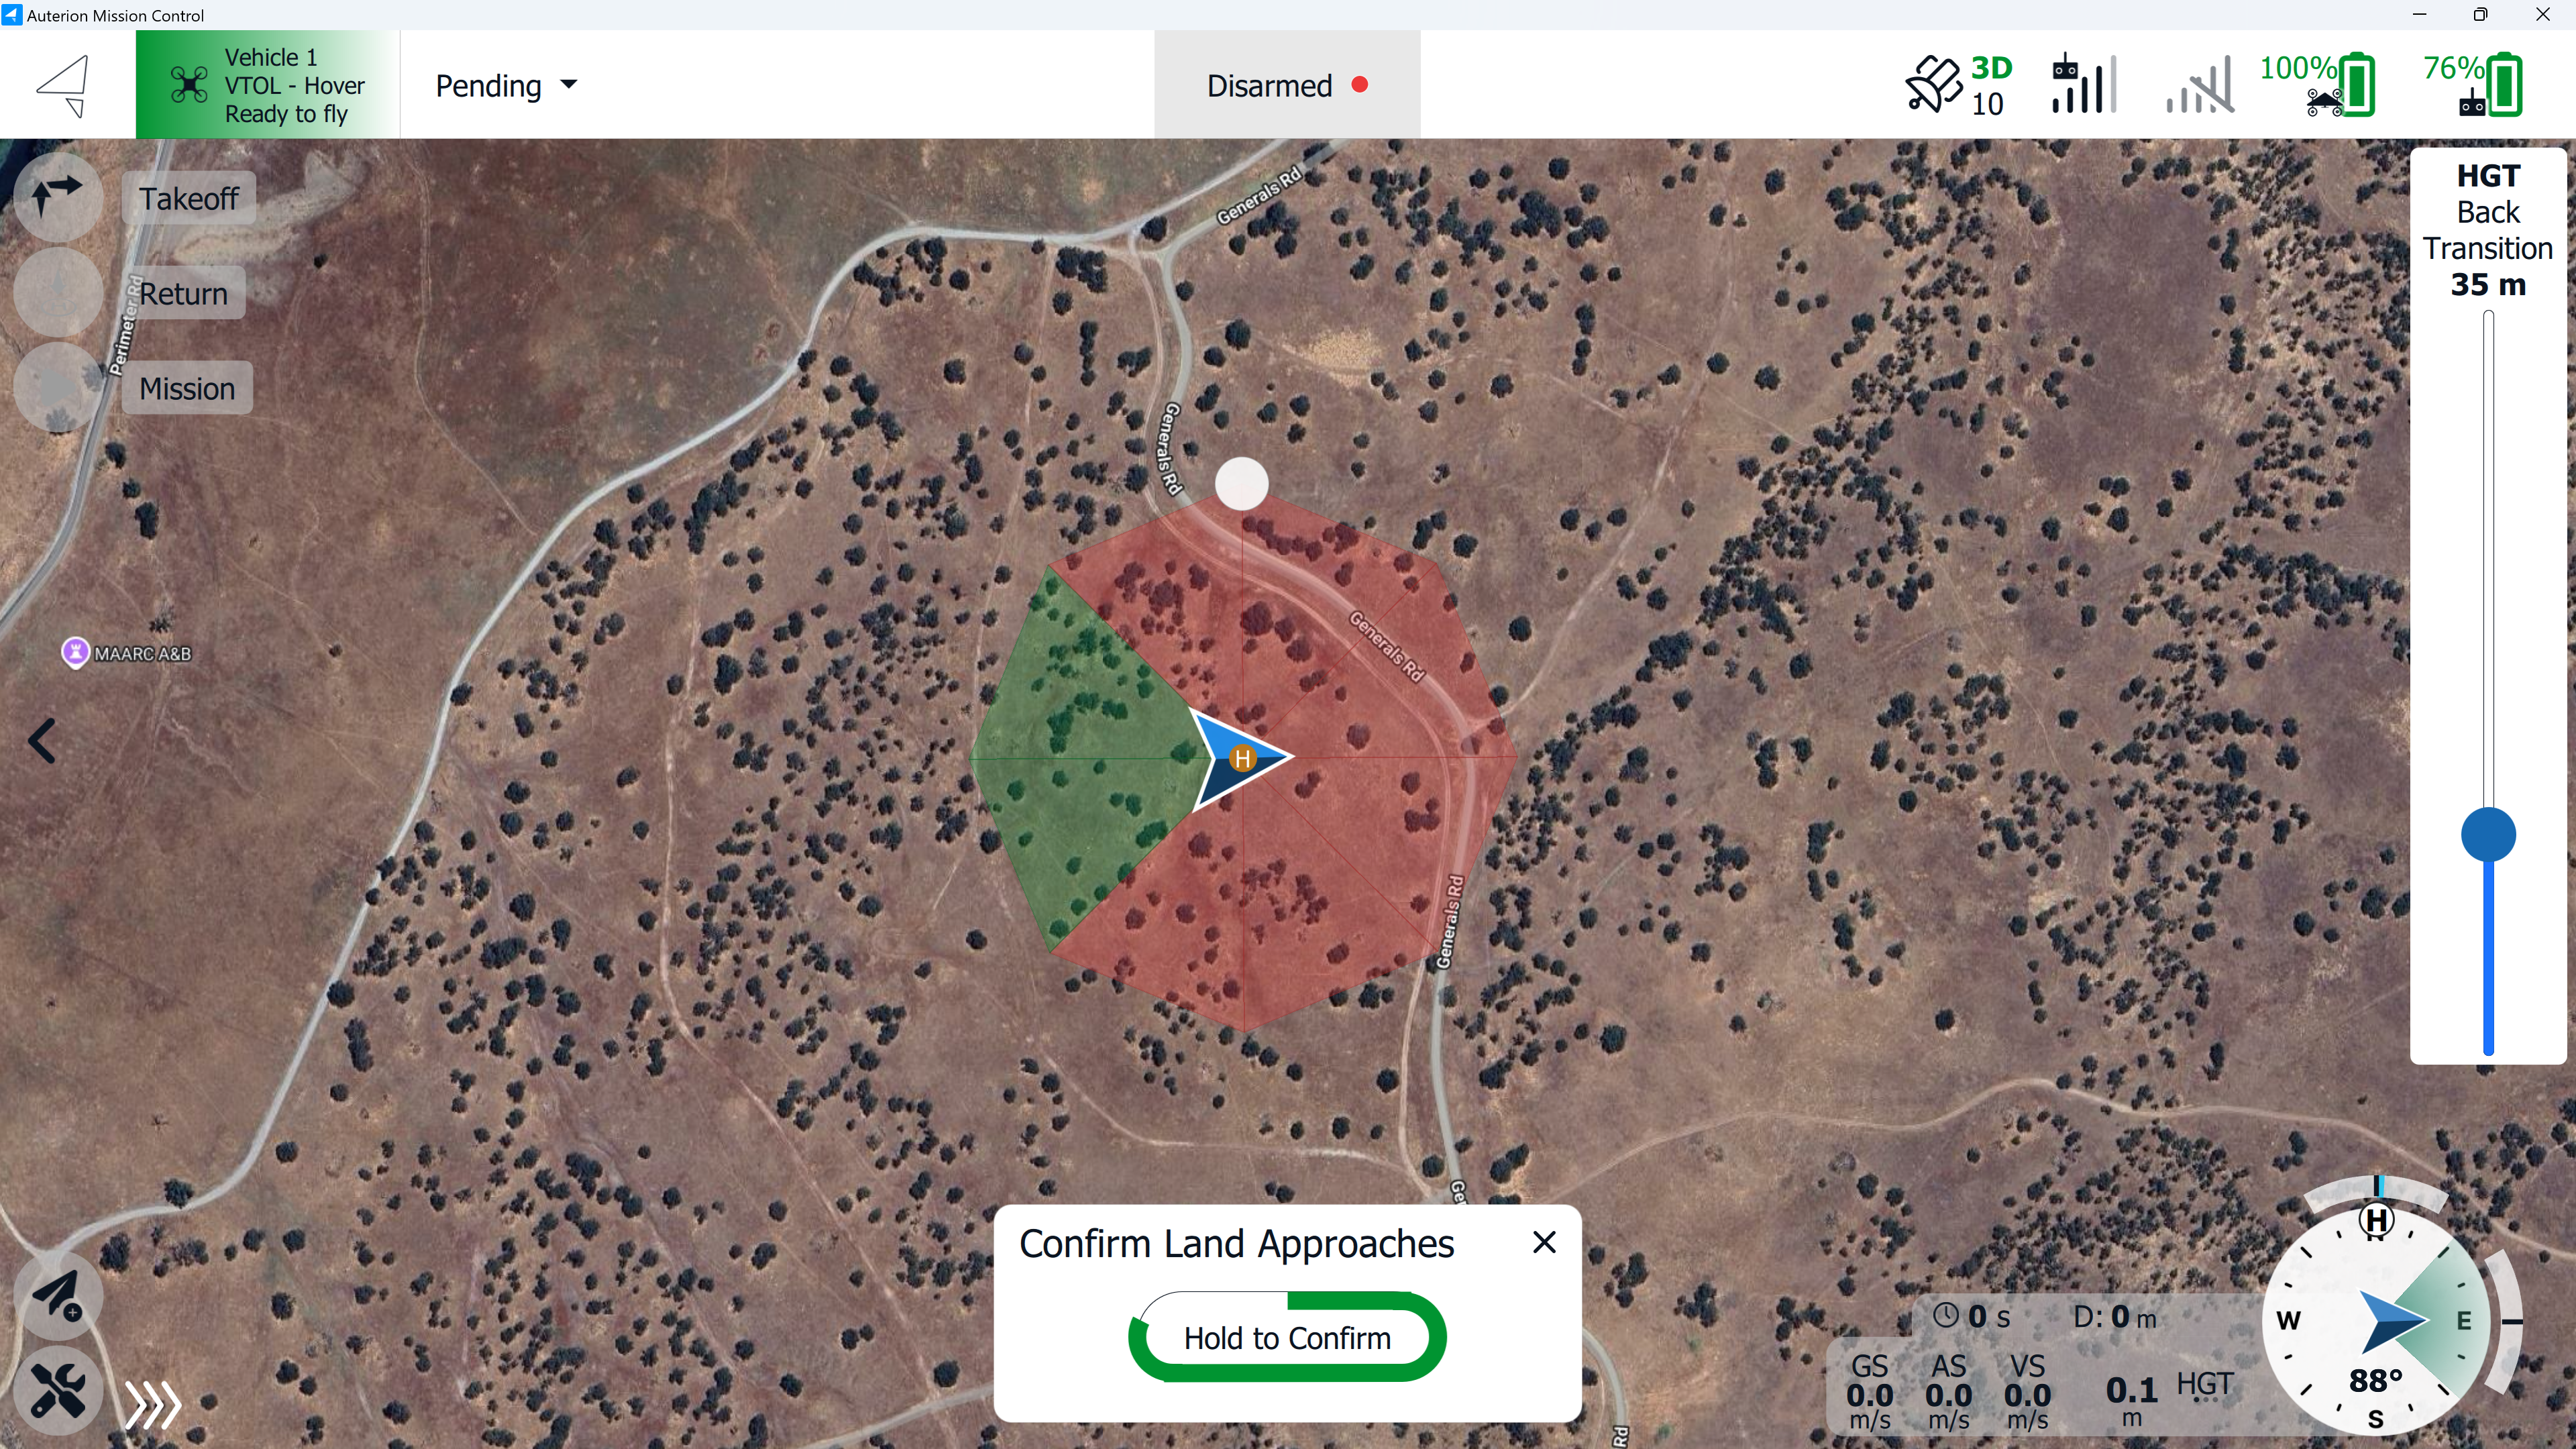
1. An **Octagon** is positioned around the vehicle, divided into 8 red sectors called **Pizza Slices**.
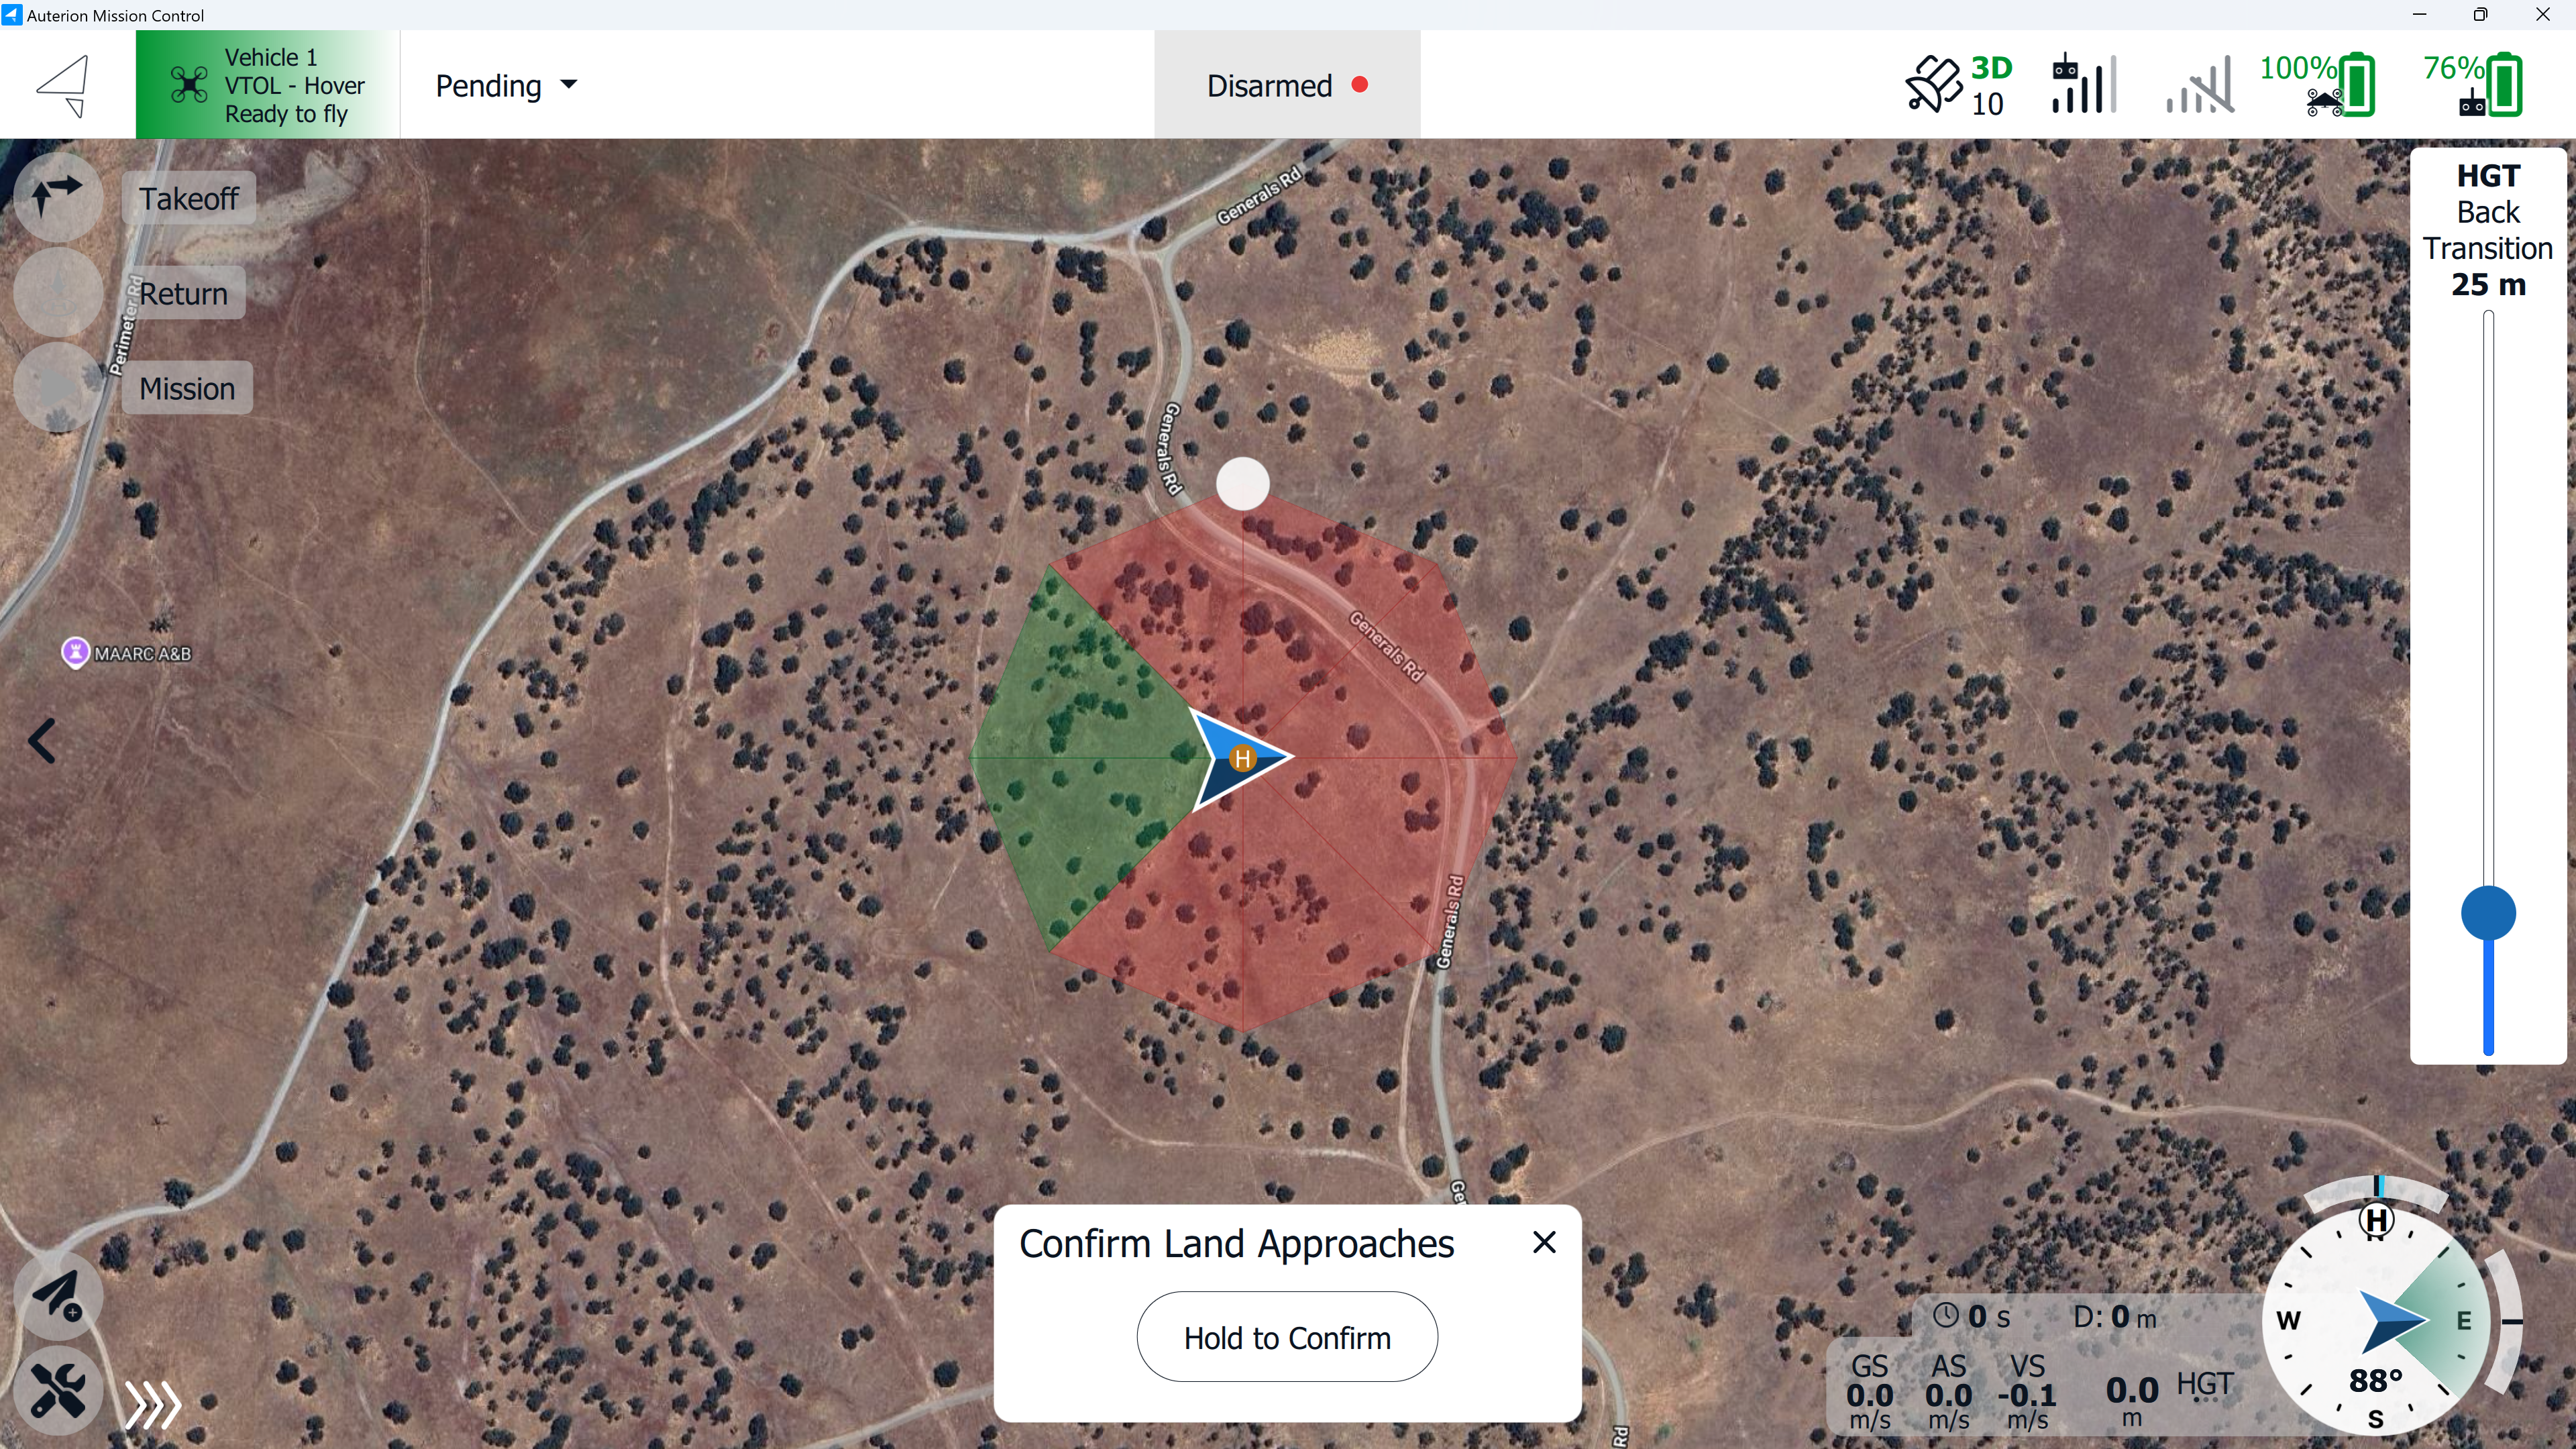
2. The first step is to assign the **sectors** where the vehicle can **loiter**, **transition**, and **land**. This is done by clicking on the relevant **sectors**. These sectors must be free of **obstacles**, and since the vehicle should take off and transition into the **wind**, **sectors** behind the vehicle should be selected. The vehicle will place the Loiter Down Orbit within the dedicated green area
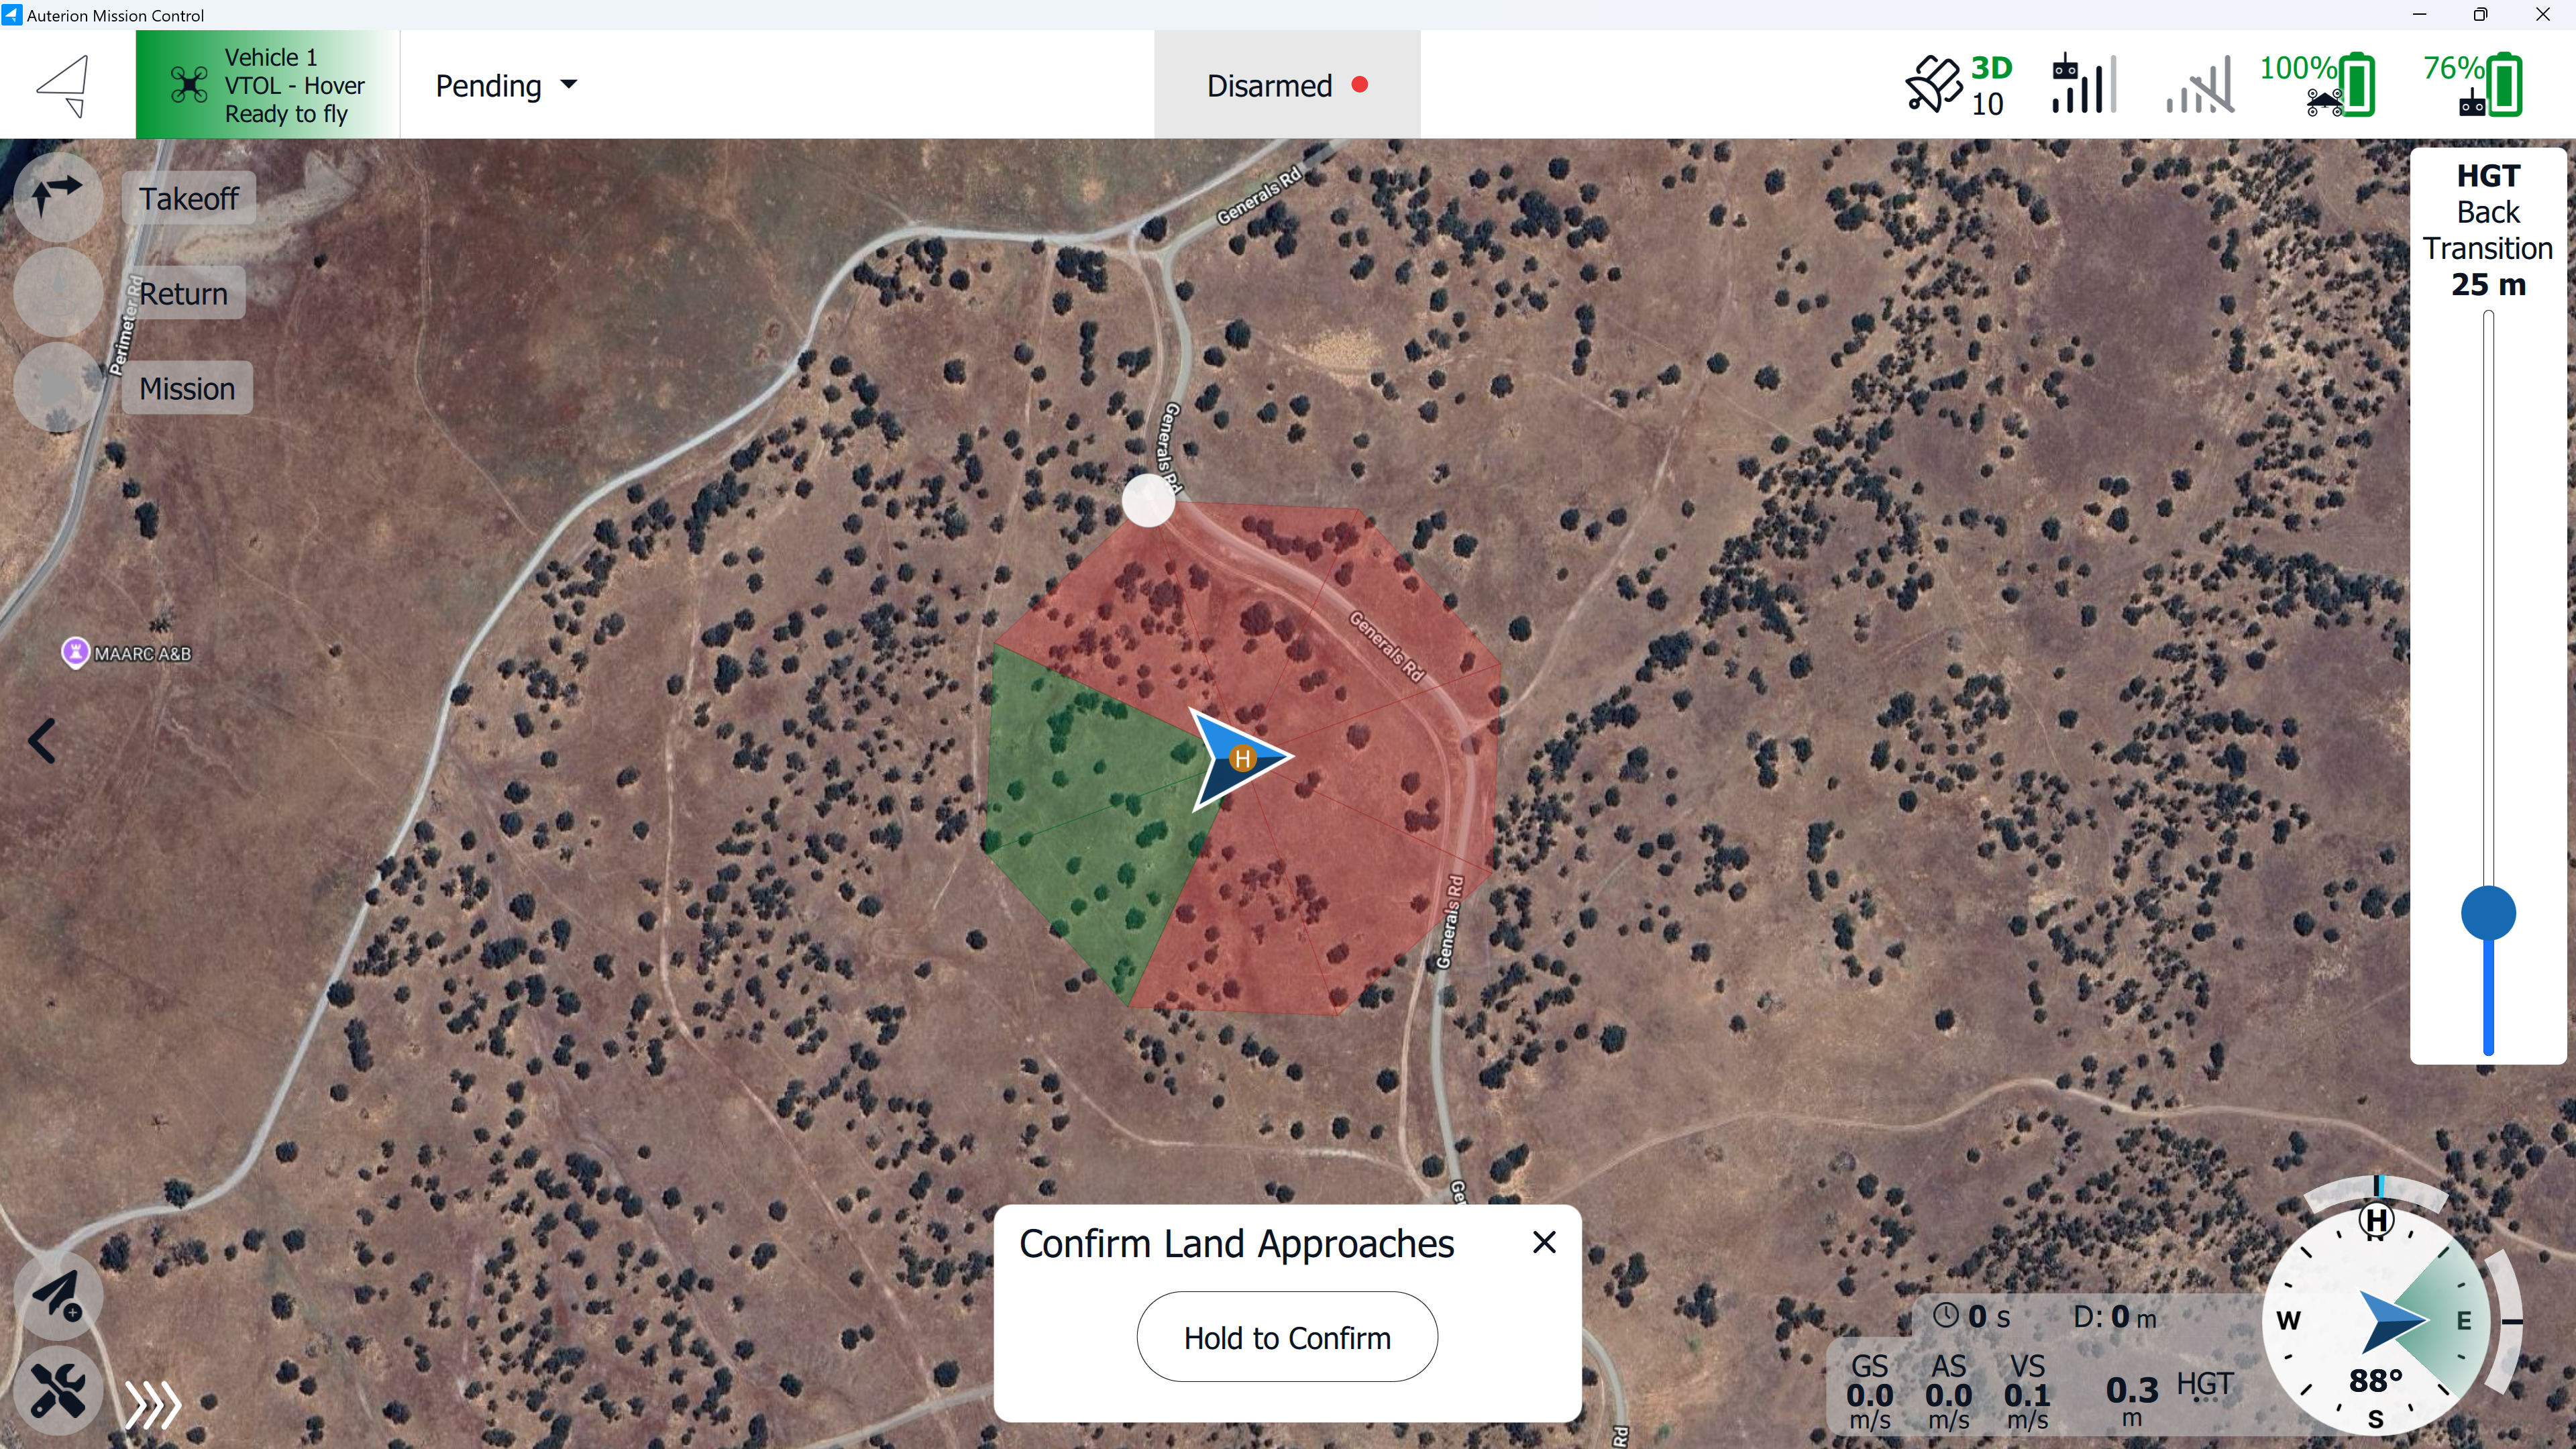
3. Grab the **vertex** at the top of the **octagon** and move it around for more **granular control**.
{% hint style="warning" %}
The vehicle places the **Loiter Down Orbit** within the dedicated **Approach Zones (green)** so the vehicle can transition and land into the wind. If this is not possible, the vehicle will choose a **Loiter Down Orbit** as close as possible to this direction, given the limitations of the selected sectors.
{% endhint %}
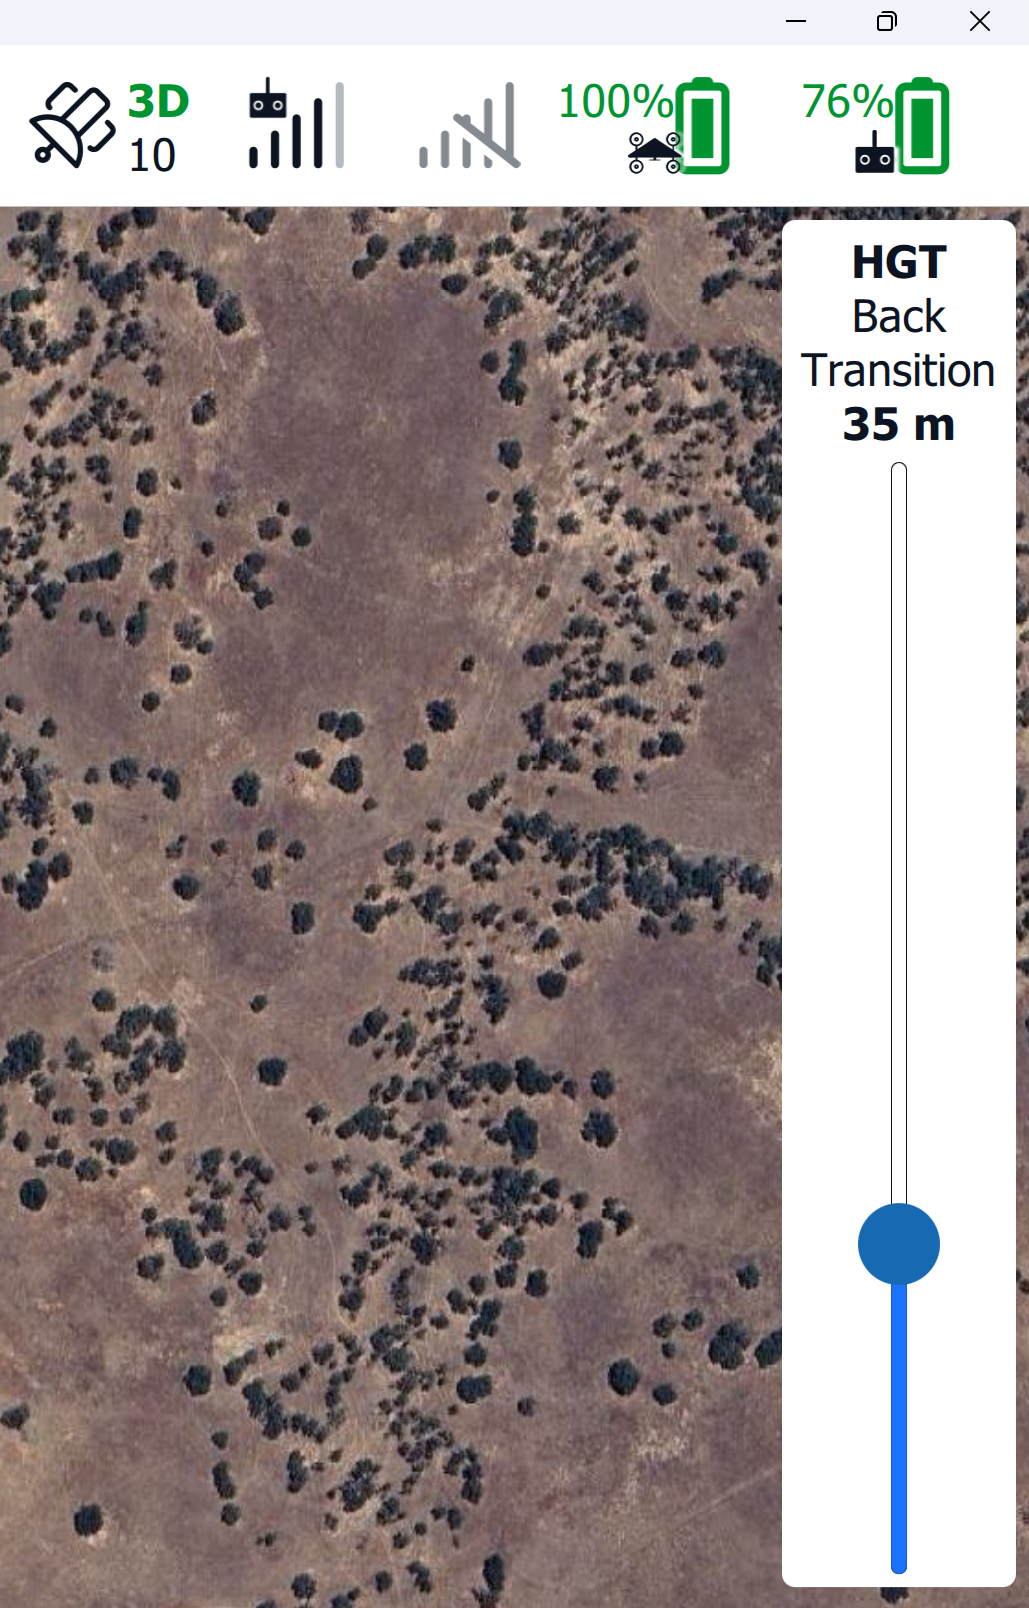
4. Set the altitude for the **Back Transition** using the **Altitude Slider** on the right side of the screen. The **Altitude Frame** is **HGT**, Height (Heights are referenced to the takeoff location).
{% hint style="warning" %}
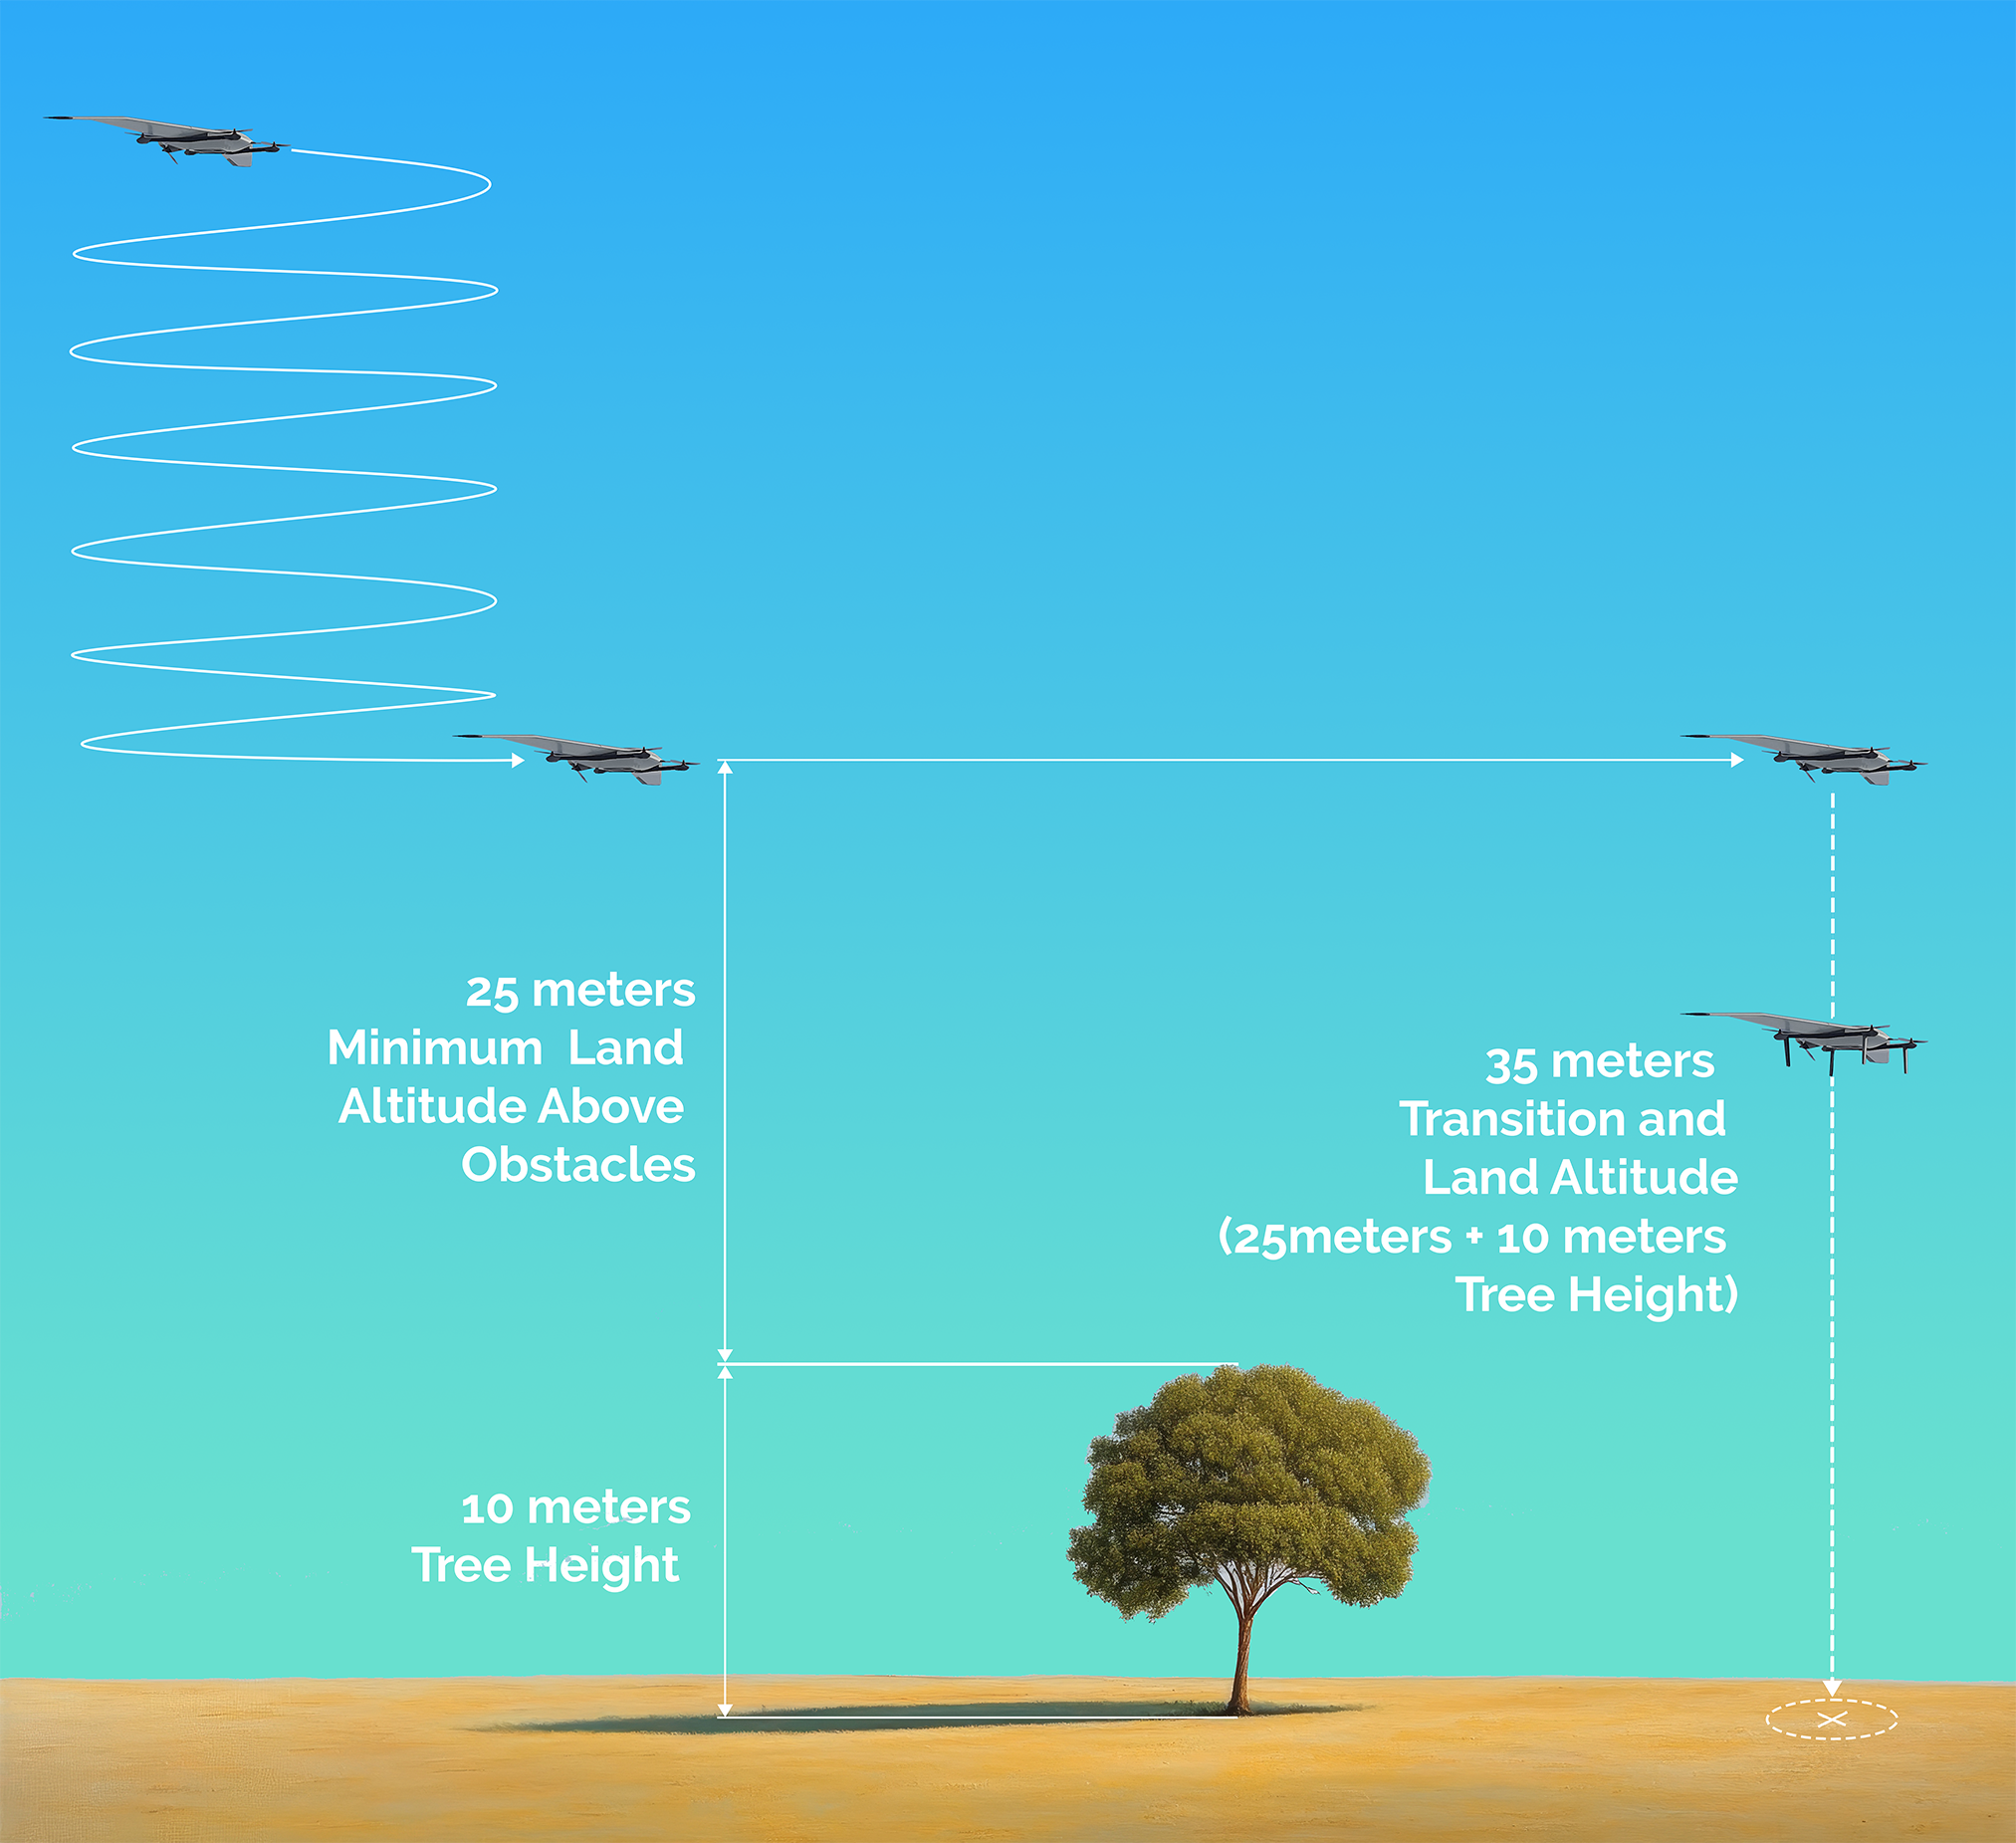
The minimum **Back Transition/Landing Altitude** to which the vehicle descends must be set at least **25 meters** above the highest obstacles in the landing area. For example, if the tallest tree in the landing area is **10 meters** high, the **Landing Altitude** must be set to at least **35 meters**.
{% endhint %}
{% hint style="info" %}
When using the **Quick Takeoff**, only the **Orbit Land Pattern** is available as a landing option. A **Straight Land Pattern** is not available.
{% endhint %}
5. **Hold** **to Confirm** the settings for the **Land Approaches**.
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.deltaquad.com/gov/flight/quick-takeoff/land-approach.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.